A task delivered by video
On 10 September 2026, NVIDIA described Skild S1. According to the partners, an operator shows a new action sequence on video and the pre-trained model uses the demonstration while performing the task. Separate retraining for every example is not required.
Showing the action
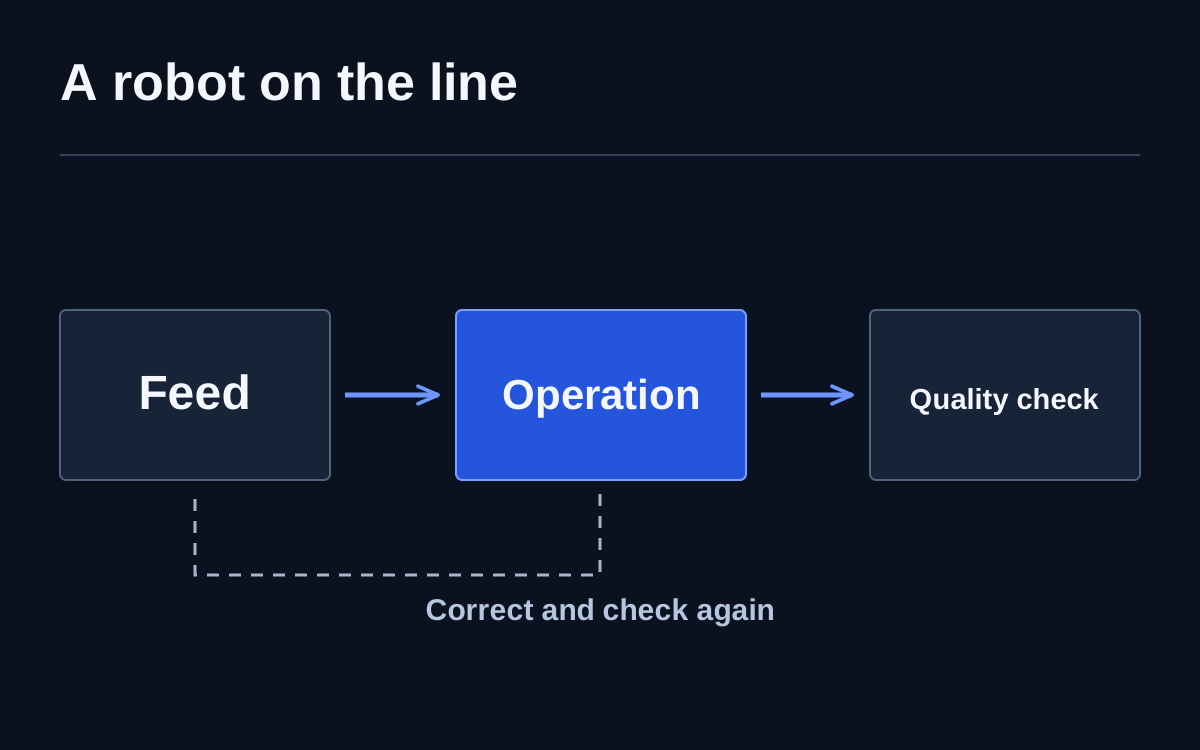
Video conveys the sequence and its goal, while the model draws on capabilities the robot already has. This links a visual instruction to machine control and reduces the amount of formal description needed to specify the sequence.
The robot and its workspace
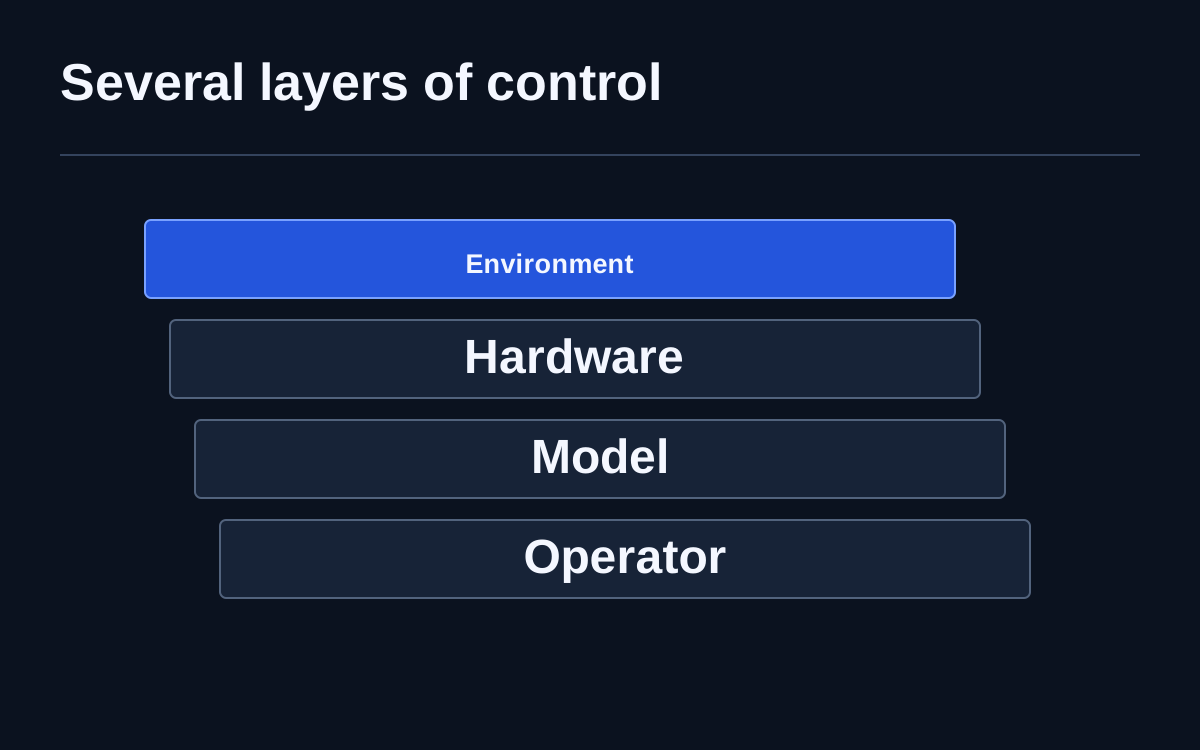
Execution depends on the robot’s available movements, the objects and the workspace. The sequence has to be related to the particular environment. The publication presents demonstrations from project participants showing how video can be used to assign tasks.
Sources
The 10 September date belongs to NVIDIA’s report. Skild’s own S1 page gives August 2026 as the release period; the sources do not establish a consistent exact launch day.